Publications
2026
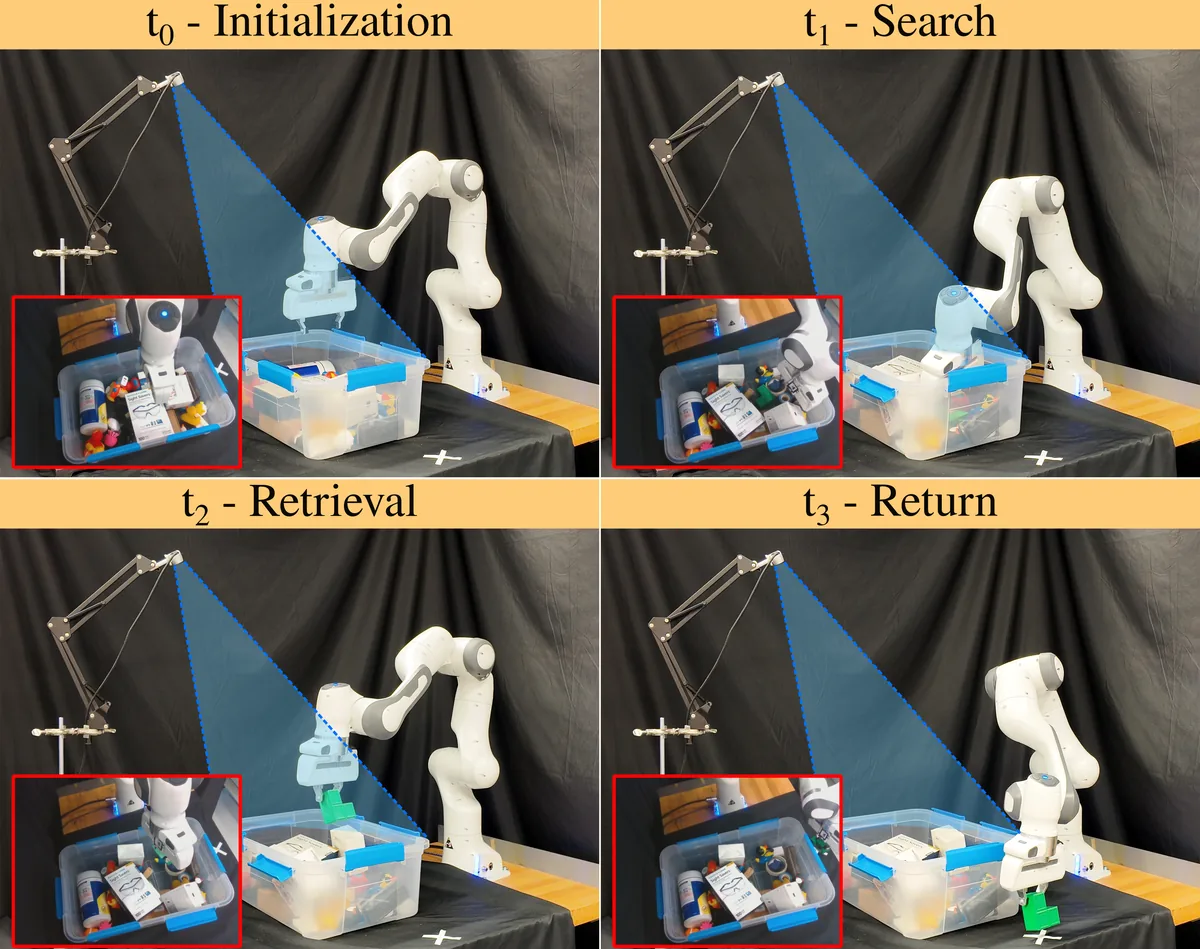
Time-Optimal Ergodic Retrieval
arXiv
·
15 Oct 2026
·
doi:10.48550/arxiv.2610.21823
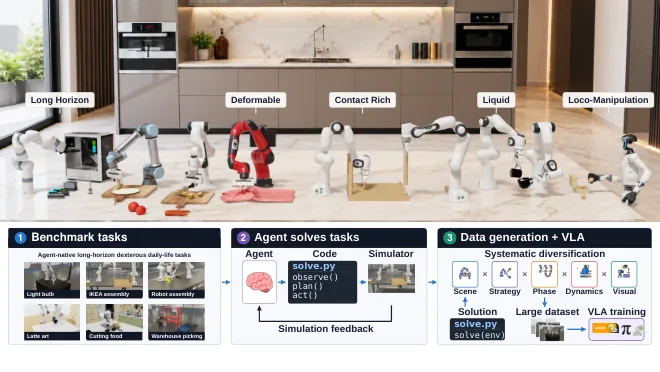
EmbodiedSWE: Coding Agents for Long Horizon Dexterous Robotics
arXiv
·
23 Sep 2026
·
doi:10.48550/arxiv.2609.27308

Accelerating Visual Policy Learning with Sampling-Based Model Predictive Control
arXiv
·
17 Sep 2026
·
doi:10.48550/arxiv.2609.20575
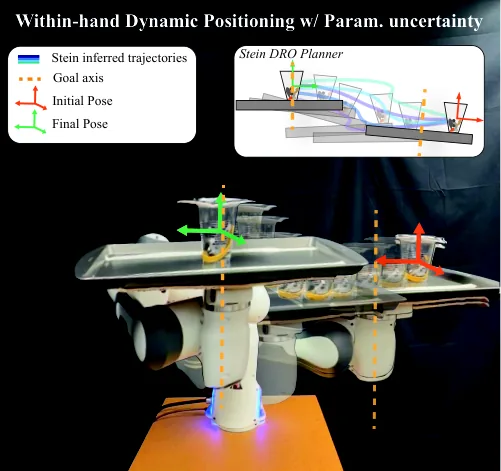
Distributionally Robust Control via Stein Variational Inference for Contact-rich Manipulation
Robotics: Science and Systems XXII
·
13 Jul 2026
·
doi:10.15607/rss.2026.xxii.061
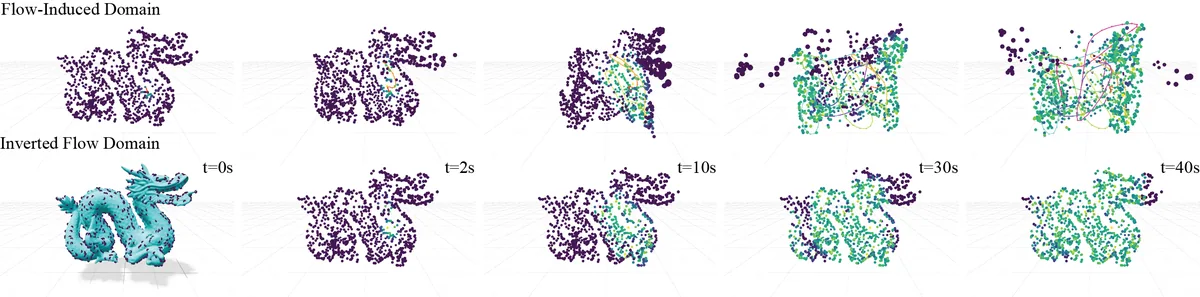
Asymptotically Optimal Ergodic Coverage on Generalized Motion Fields
Robotics: Science and Systems XXII
·
13 Jul 2026
·
doi:10.15607/rss.2026.xxii.136
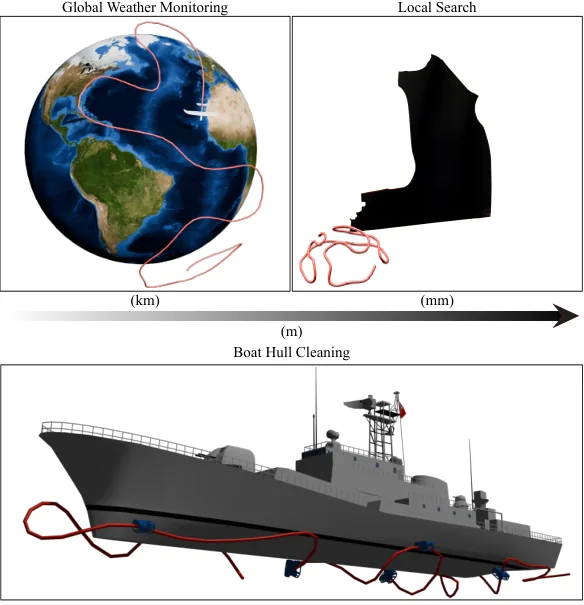
Search at Scale: Improving Numerical Conditioning of Ergodic Coverage Optimization for Multi-Scale Domains
2026 IEEE International Conference on Robotics and Automation (ICRA)
·
01 Jun 2026
·
doi:10.1109/icra57385.2026.11697230
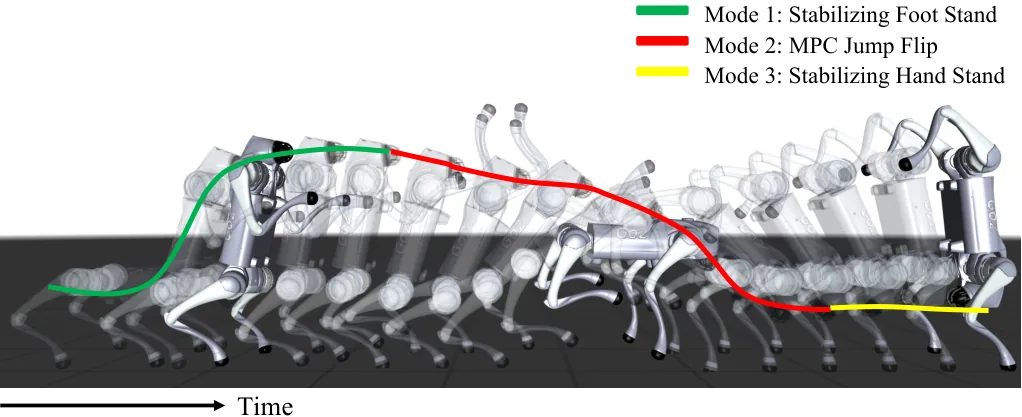
Sample-Based Hybrid Mode Control: Asymptotically Optimal Switching of Algorithmic and Non-Differentiable Control Modes
2026 IEEE International Conference on Robotics and Automation (ICRA)
·
01 Jun 2026
·
doi:10.1109/icra57385.2026.11696777
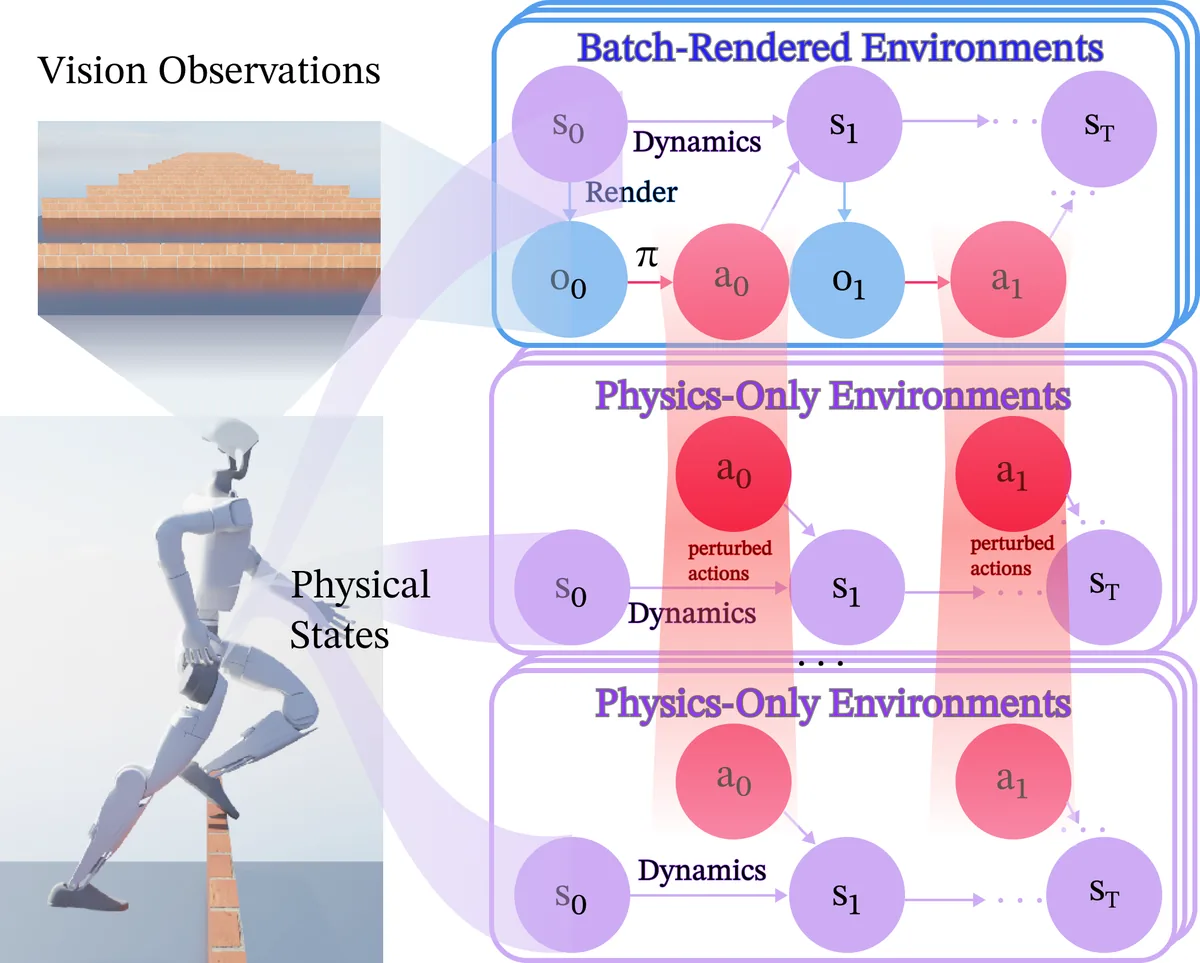
Efficient On-policy Visual-RL via Stochastic Decoupled Policy Gradient
arXiv
·
26 May 2026
·
doi:10.48550/arxiv.2605.26478
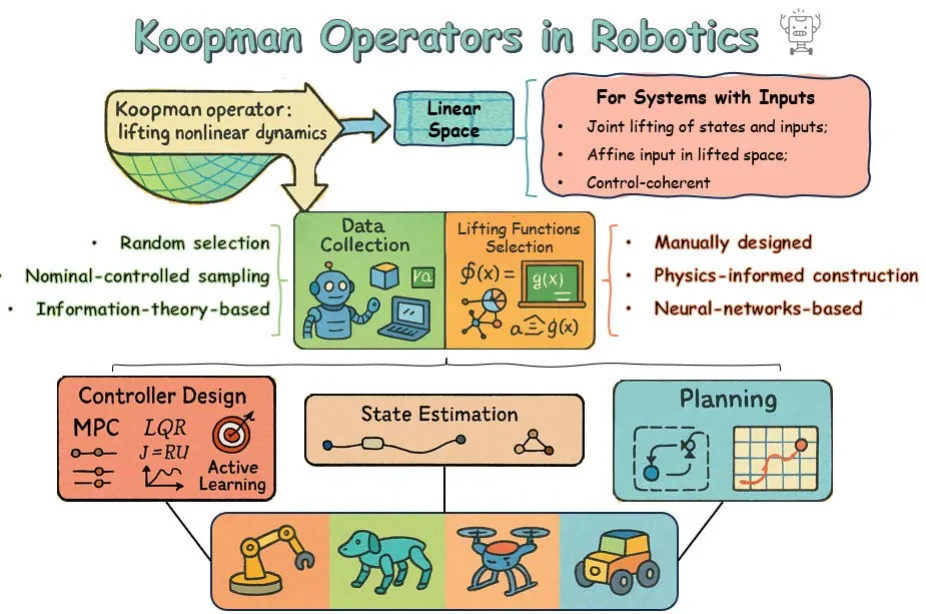
Koopman Operators in Robot Learning
IEEE Transactions on Robotics
·
01 Jan 2026
·
doi:10.1109/TRO.2026.3654384
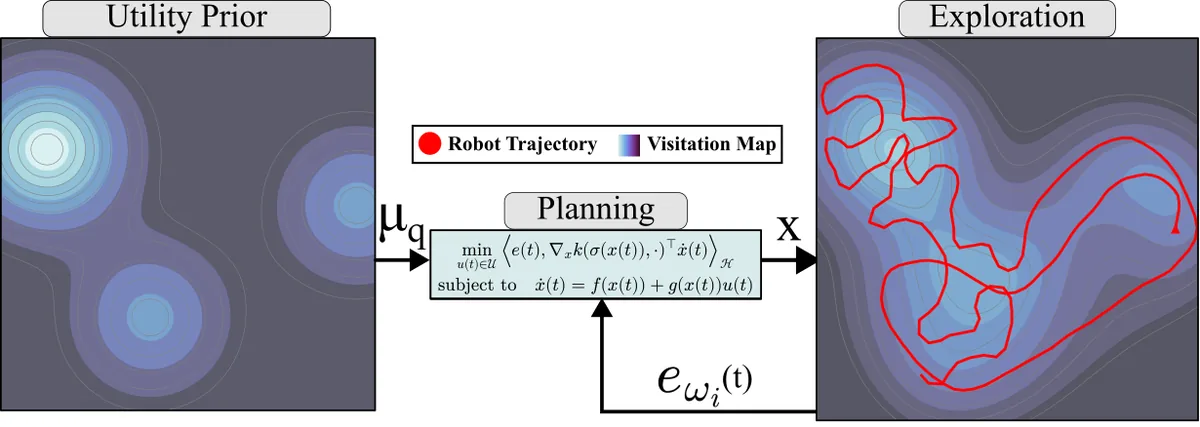
Infinite-Horizon Ergodic Control via Kernel Mean Embeddings
arXiv
·
01 Jan 2026
·
doi:10.48550/arxiv.2604.01023
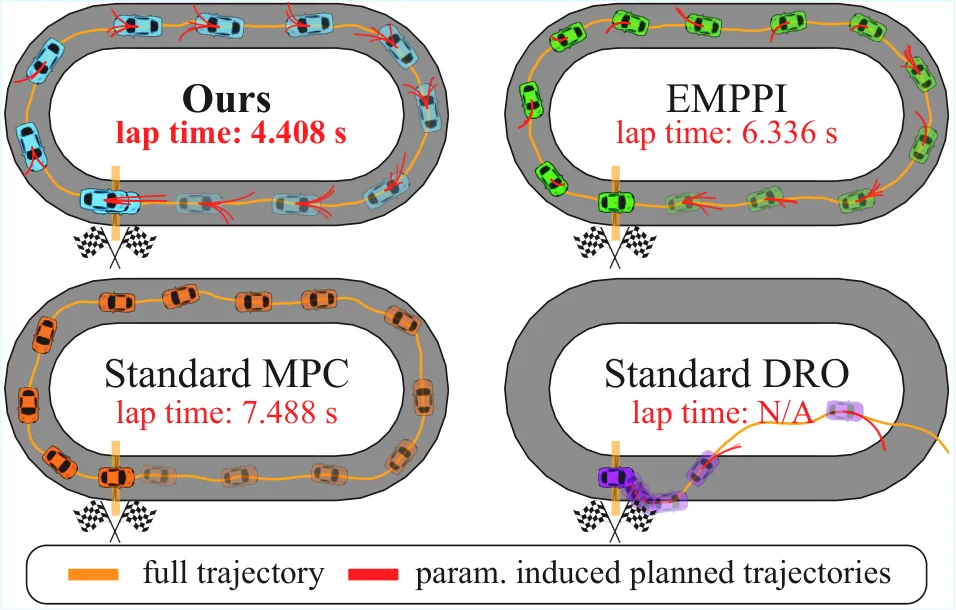
Stein Variational Uncertainty-Adaptive Model Predictive Control
arXiv
·
01 Jan 2026
·
doi:10.48550/arxiv.2604.01034
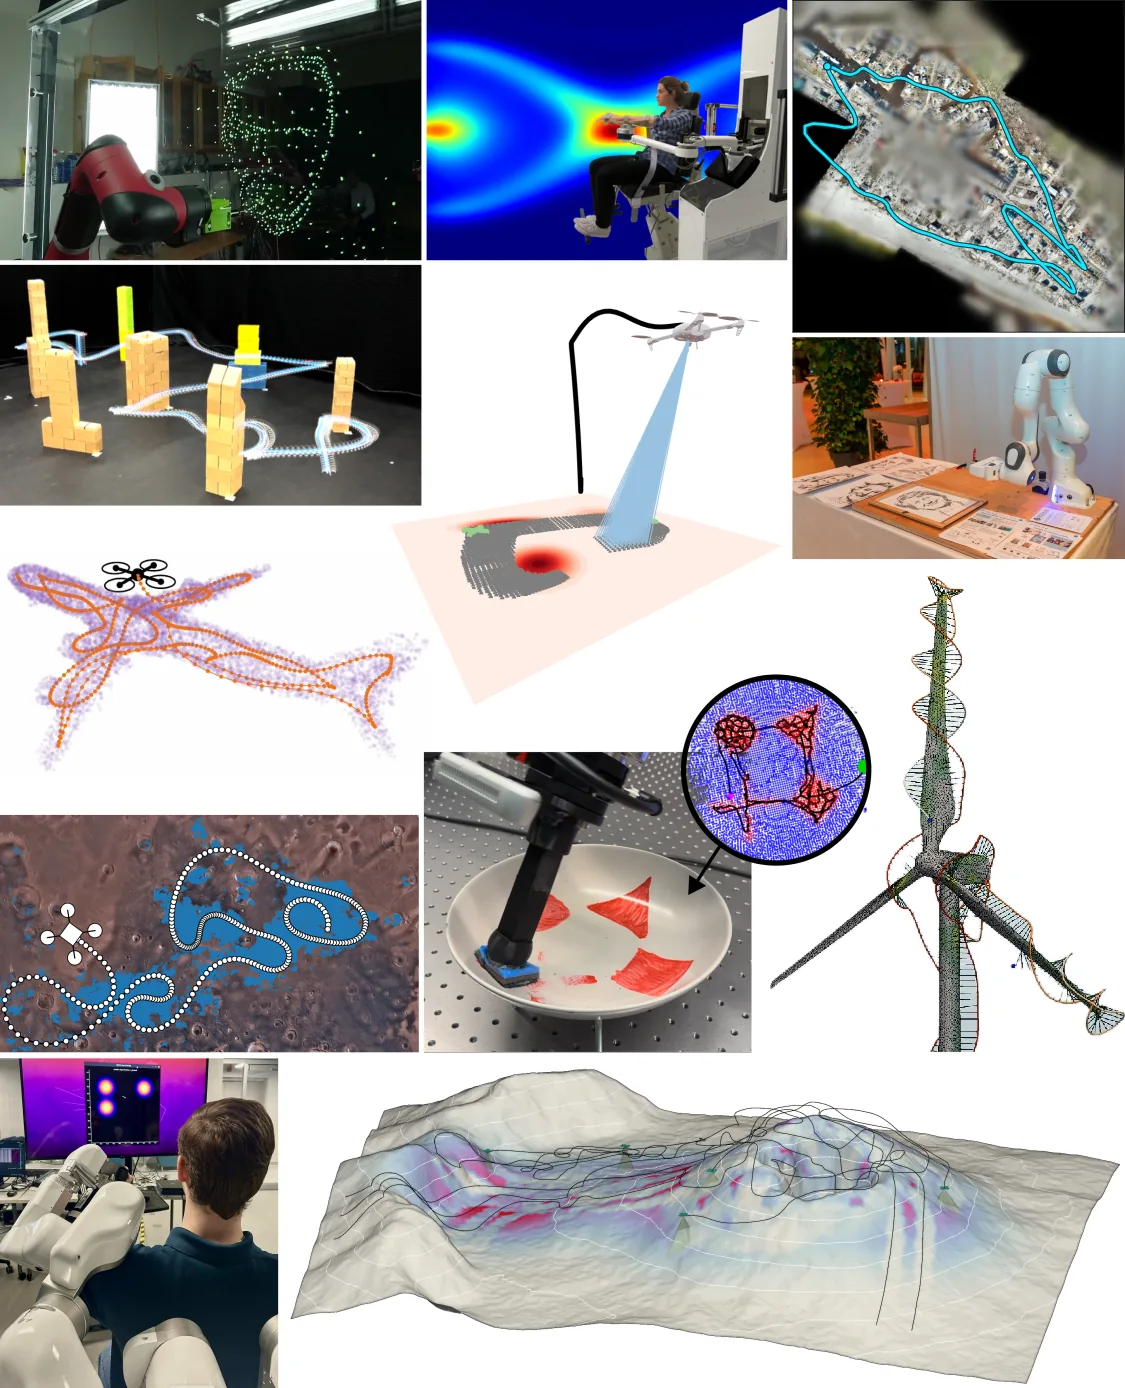
Ergodic Control and Controlled Diffusion for Robot Learning: Review and Tutorial
arXiv
·
01 Jan 2026
·
doi:10.48550/arxiv.2609.13295
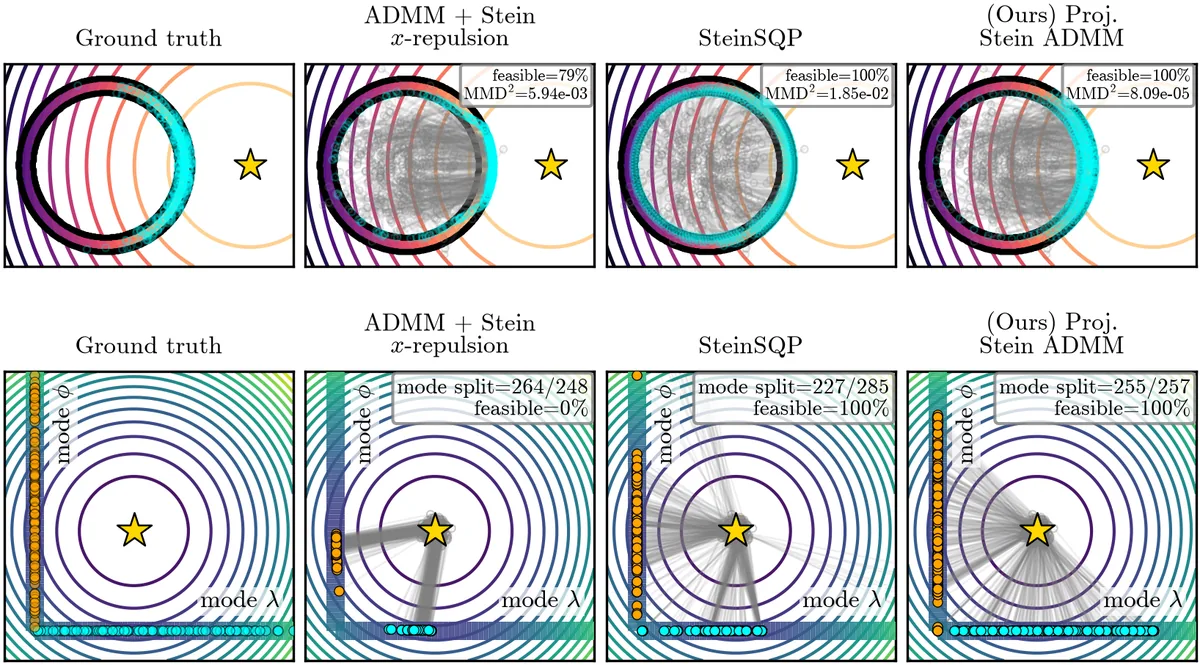
Contact-Implicit Stein Projected ADMM for Discovery of Diverse Contact-Rich Manipulation Strategies
arXiv
·
01 Jan 2026
·
doi:10.48550/arxiv.2609.28299
2025
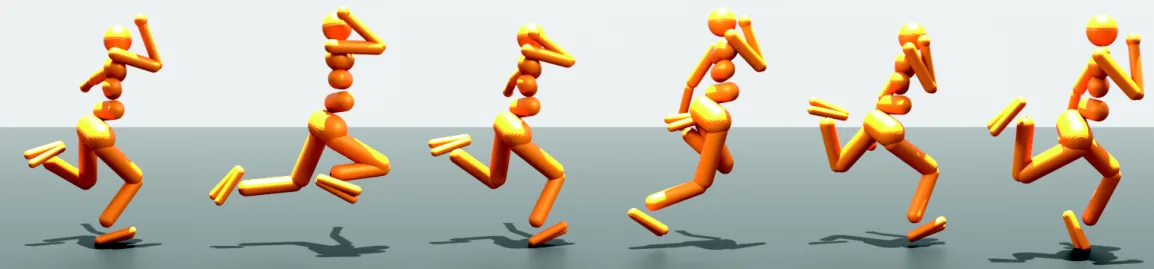
Accelerating Visual-Policy Learning through Parallel Differentiable Simulation
Advances in Neural Information Processing Systems 38
·
02 Dec 2025
·
source-work-id:755432
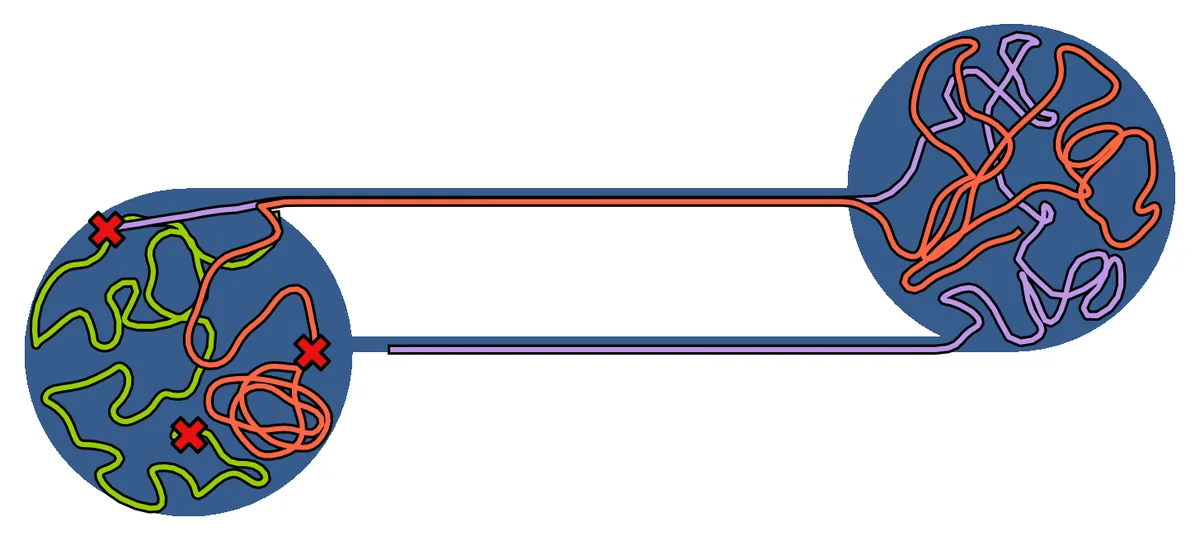
Measure Preserving Flows for Ergodic Search in Convoluted Environments
Springer Proceedings in Advanced Robotics
·
02 Nov 2025
·
doi:10.1007/978-3-032-04584-3_38
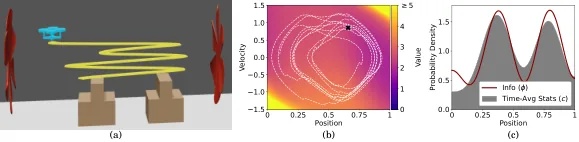
RAnGE: Reachability Analysis for Guaranteed Ergodicity
Springer Proceedings in Advanced Robotics
·
30 Oct 2025
·
doi:10.1007/978-3-032-09967-9_20
3D Reprojection-Driven Robot Navigation Improves Depth Sensing
2025 International Conference on Advanced Robotics and Mechatronics (ICARM)
·
01 Aug 2025
·
doi:10.1109/icarm65671.2025.11293600
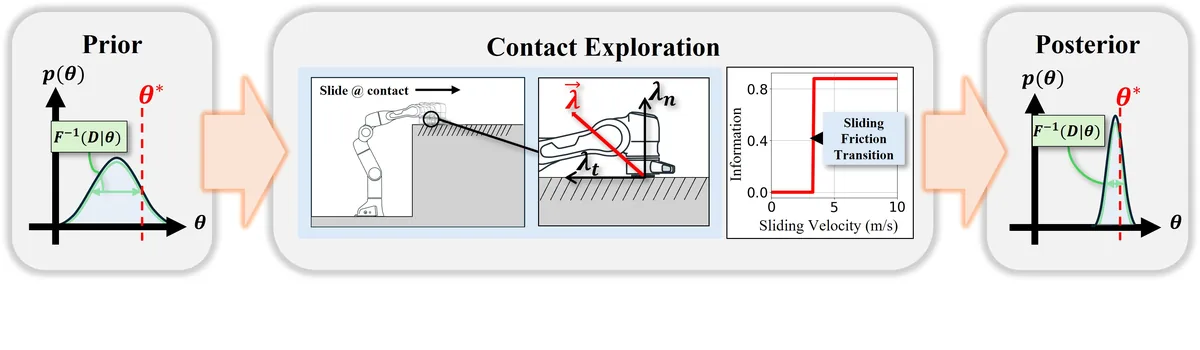
Behavior Synthesis via Contact-Aware Fisher Information Maximization
Robotics: Science and Systems XXI
·
21 Jun 2025
·
doi:10.15607/rss.2025.xxi.118
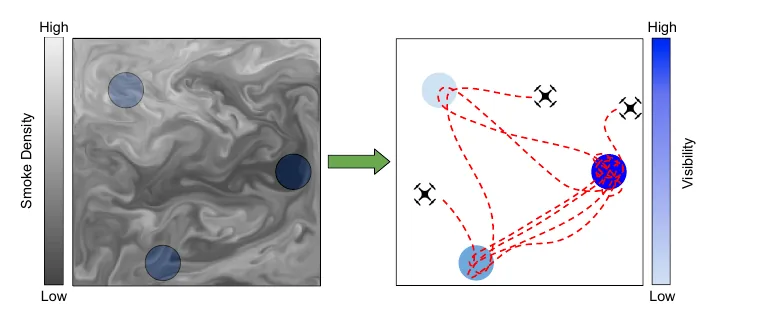
Multi-Agent Ergodic Exploration Under Smoke-Based Time-Varying Sensor Visibility Constraints
2025 IEEE International Conference on Robotics and Automation (ICRA)
·
19 May 2025
·
doi:10.1109/icra55743.2025.11128670
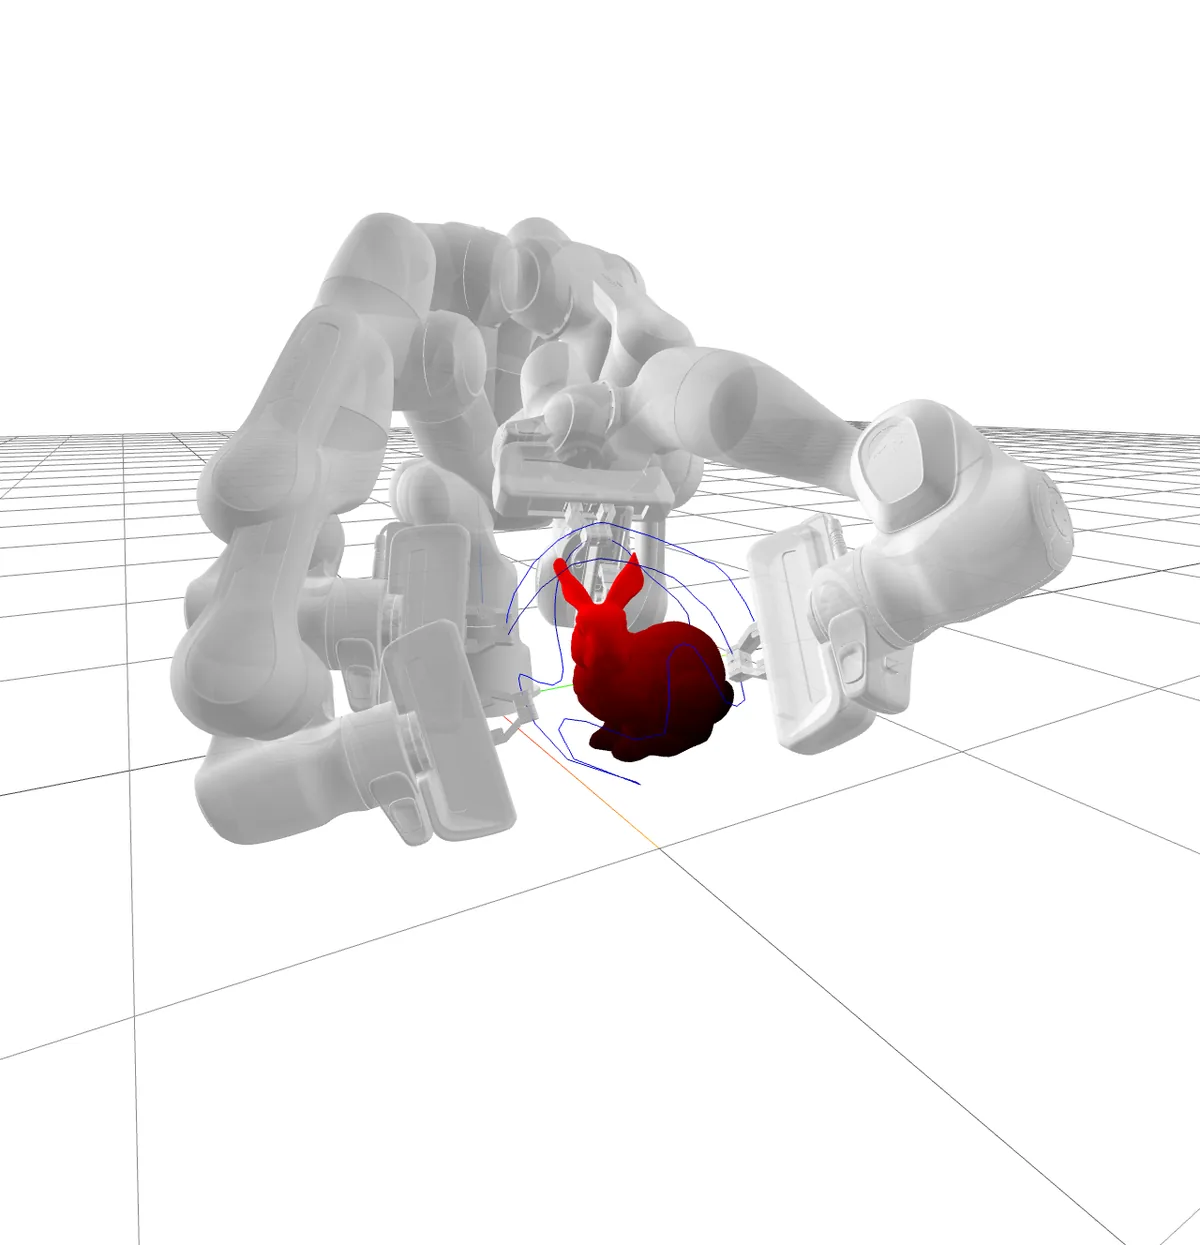
Ergodic Trajectory Optimization on Generalized Domains Using Maximum Mean Discrepancy
2025 IEEE International Conference on Robotics and Automation (ICRA)
·
19 May 2025
·
doi:10.1109/icra55743.2025.11127573
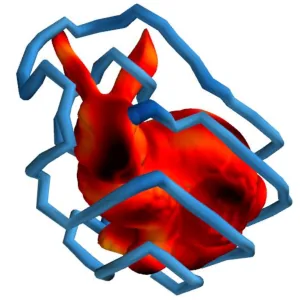
Ergodic Exploration over Meshable Surfaces
2025 IEEE International Conference on Robotics and Automation (ICRA)
·
19 May 2025
·
doi:10.1109/icra55743.2025.11127626
Diversifying Parallel Ergodic Search: A Signature Kernel Evolution Strategy
Advances in Neural Information Processing Systems 38
·
01 Jan 2025
·
doi:10.52202/085713-2482
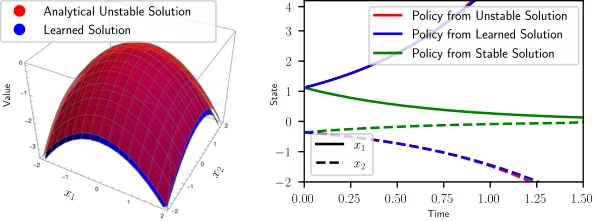
Is Bellman Equation Enough for Learning Control?
arXiv
·
01 Jan 2025
·
doi:10.48550/arxiv.2503.02171
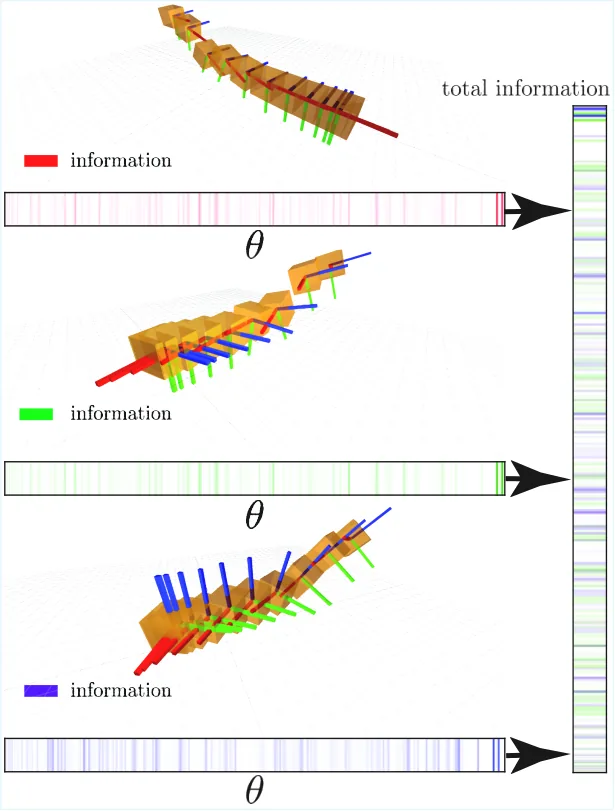
Quality Over Quantity: Curating Contact-Based Robot Datasets Improves Learning
arXiv
·
01 Jan 2025
·
doi:10.48550/arxiv.2510.18137
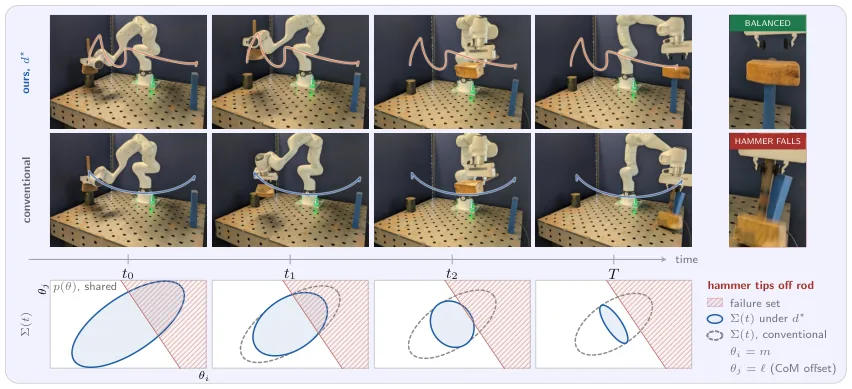
Learning On The Job: Zero-Shot Task Execution under Parametric Uncertainty via Trajectory-Parametrized Dual Control
arXiv
·
01 Jan 2025
·
doi:10.48550/arxiv.2510.20483
2024
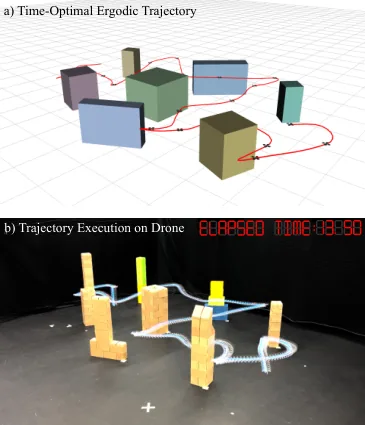
Time-optimal ergodic search: Multiscale coverage in minimum time
The International Journal of Robotics Research
·
08 Oct 2024
·
doi:10.1177/02783649241273597
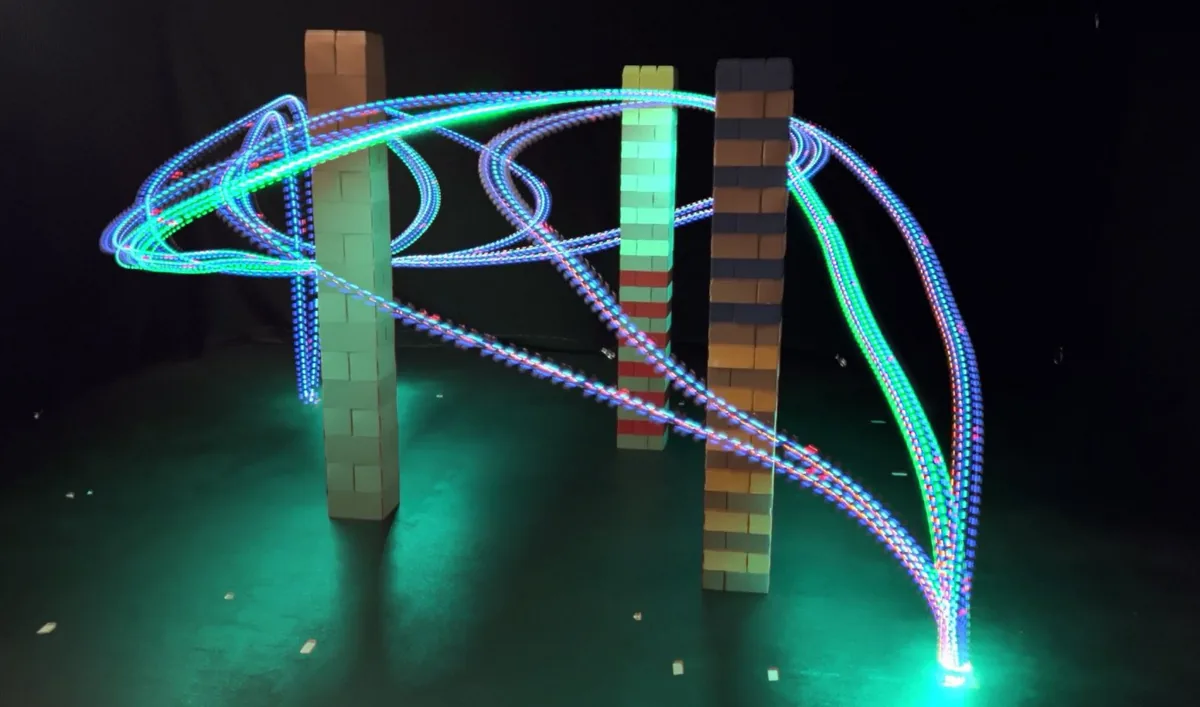
Stein Variational Ergodic Search
Robotics: Science and Systems XX
·
15 Jul 2024
·
doi:10.15607/rss.2024.xx.001
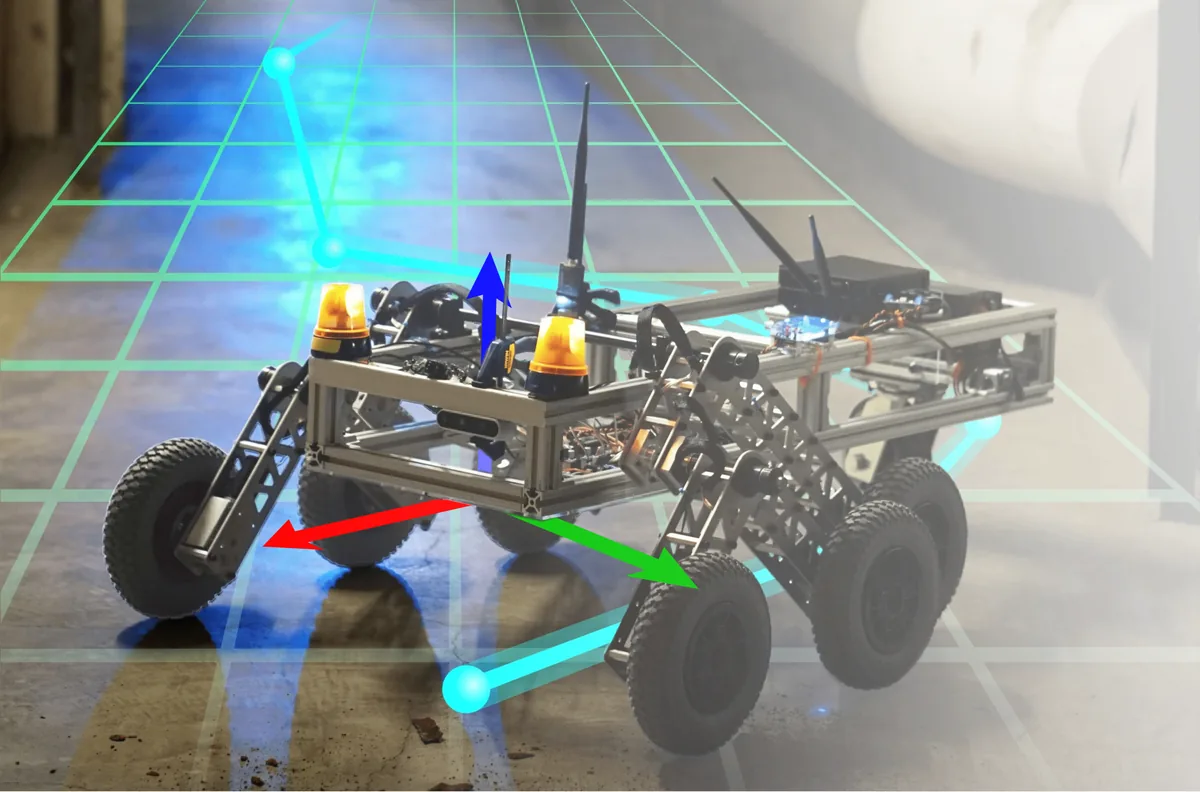
RB5 Low-Cost Explorer: Implementing Autonomous Long-Term Exploration on Low-Cost Robotic Hardware
2024 IEEE International Conference on Robotics and Automation (ICRA)
·
13 May 2024
·
doi:10.1109/icra57147.2024.10610399
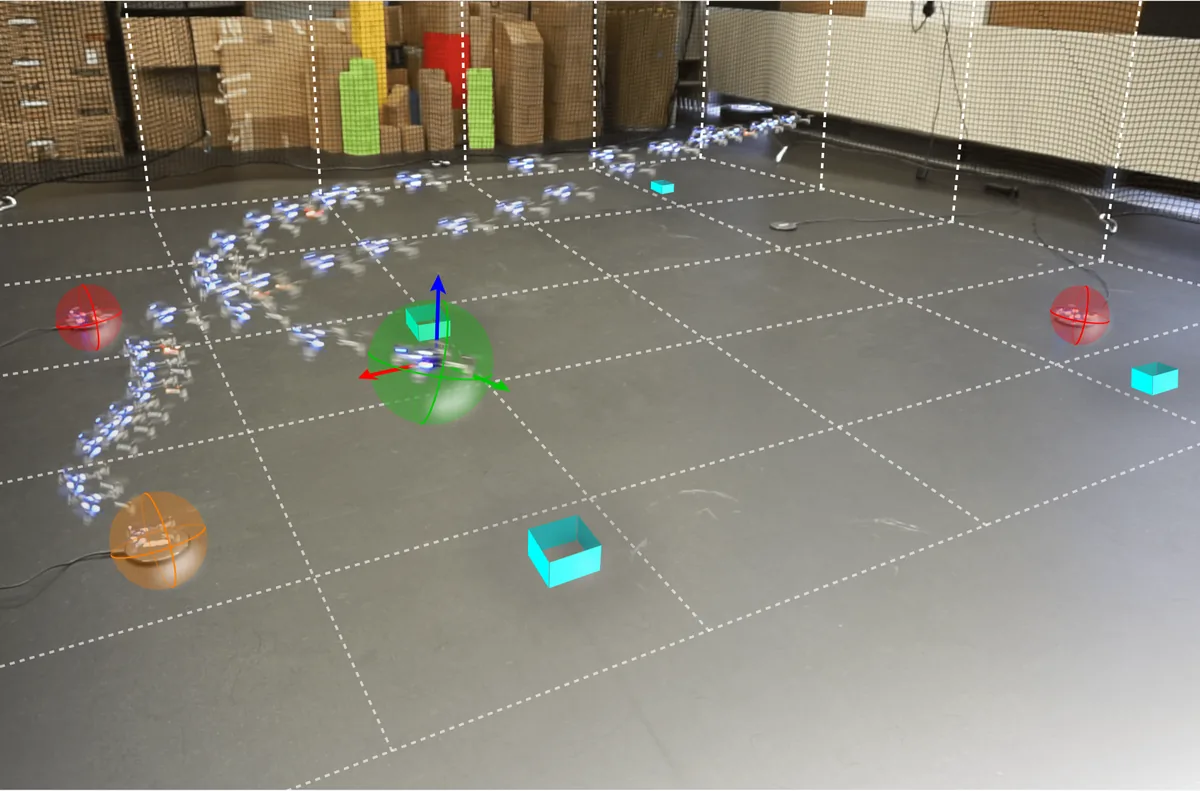
Energy-Aware Ergodic Search: Continuous Exploration for Multi-Agent Systems with Battery Constraints
2024 IEEE International Conference on Robotics and Automation (ICRA)
·
13 May 2024
·
doi:10.1109/icra57147.2024.10609871
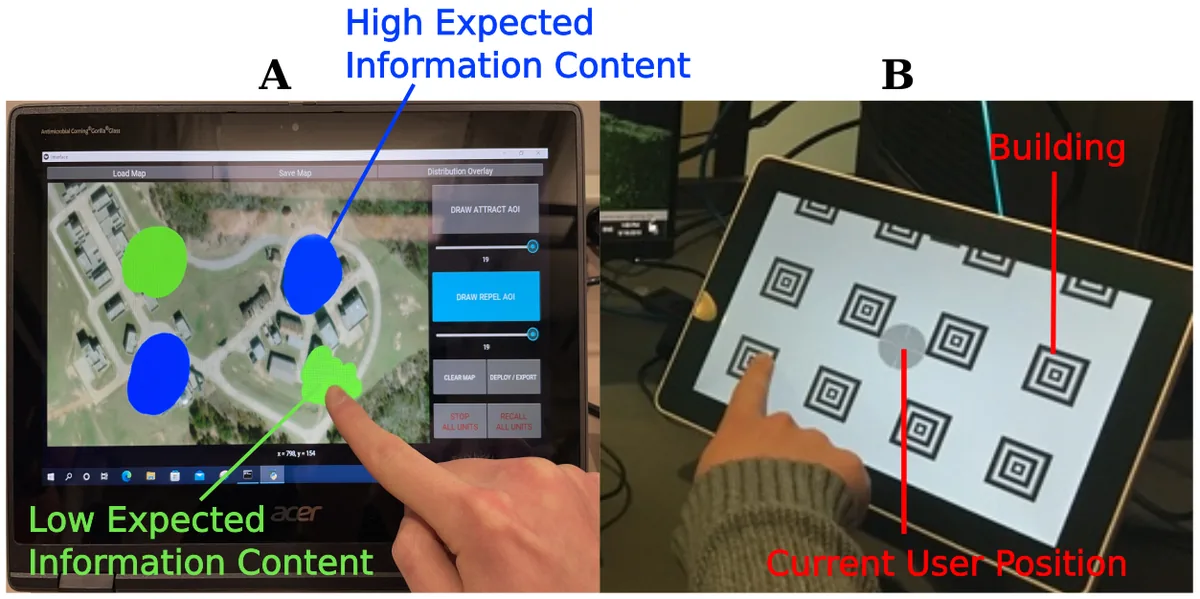
Scale-Invariant Specifications for Human–Swarm Systems
IEEE Transactions on Field Robotics
·
01 Jan 2024
·
doi:10.55417/fr.2023011
Sparse Sensing in Ergodic Optimization
Springer Proceedings in Advanced Robotics
·
01 Jan 2024
·
doi:10.1007/978-3-031-51497-5_9
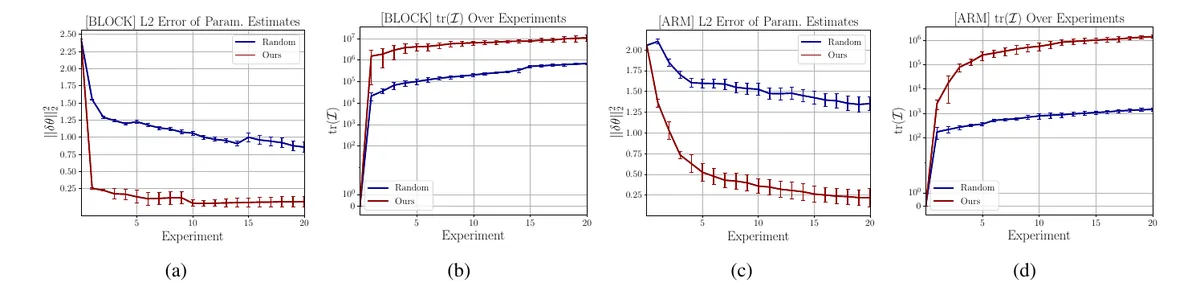
Exciting Contact Modes in Differentiable Simulations for Robot Learning
arXiv
·
01 Jan 2024
·
doi:10.48550/arxiv.2411.10935
2023
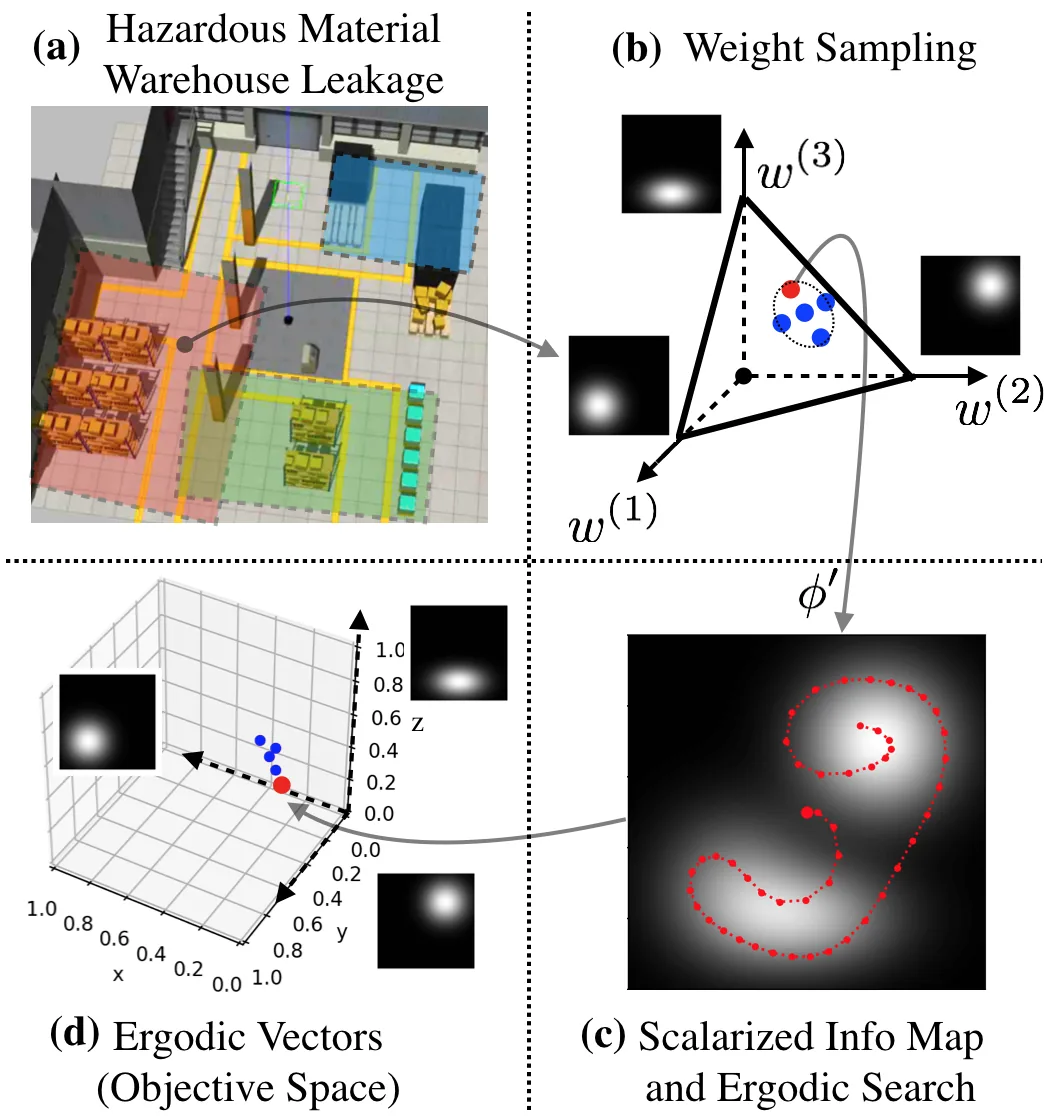
A Pareto-Optimal Local Optimization Framework for Multiobjective Ergodic Search
IEEE Transactions on Robotics
·
01 Oct 2023
·
doi:10.1109/TRO.2023.3284358
Multi-Agent Multi-Objective Ergodic Search Using Branch and Bound
2023 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)
·
01 Oct 2023
·
doi:10.1109/iros55552.2023.10341353
Bi-Level Image-Guided Ergodic Exploration with Applications to Planetary Rovers
2023 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)
·
01 Oct 2023
·
doi:10.1109/iros55552.2023.10341437
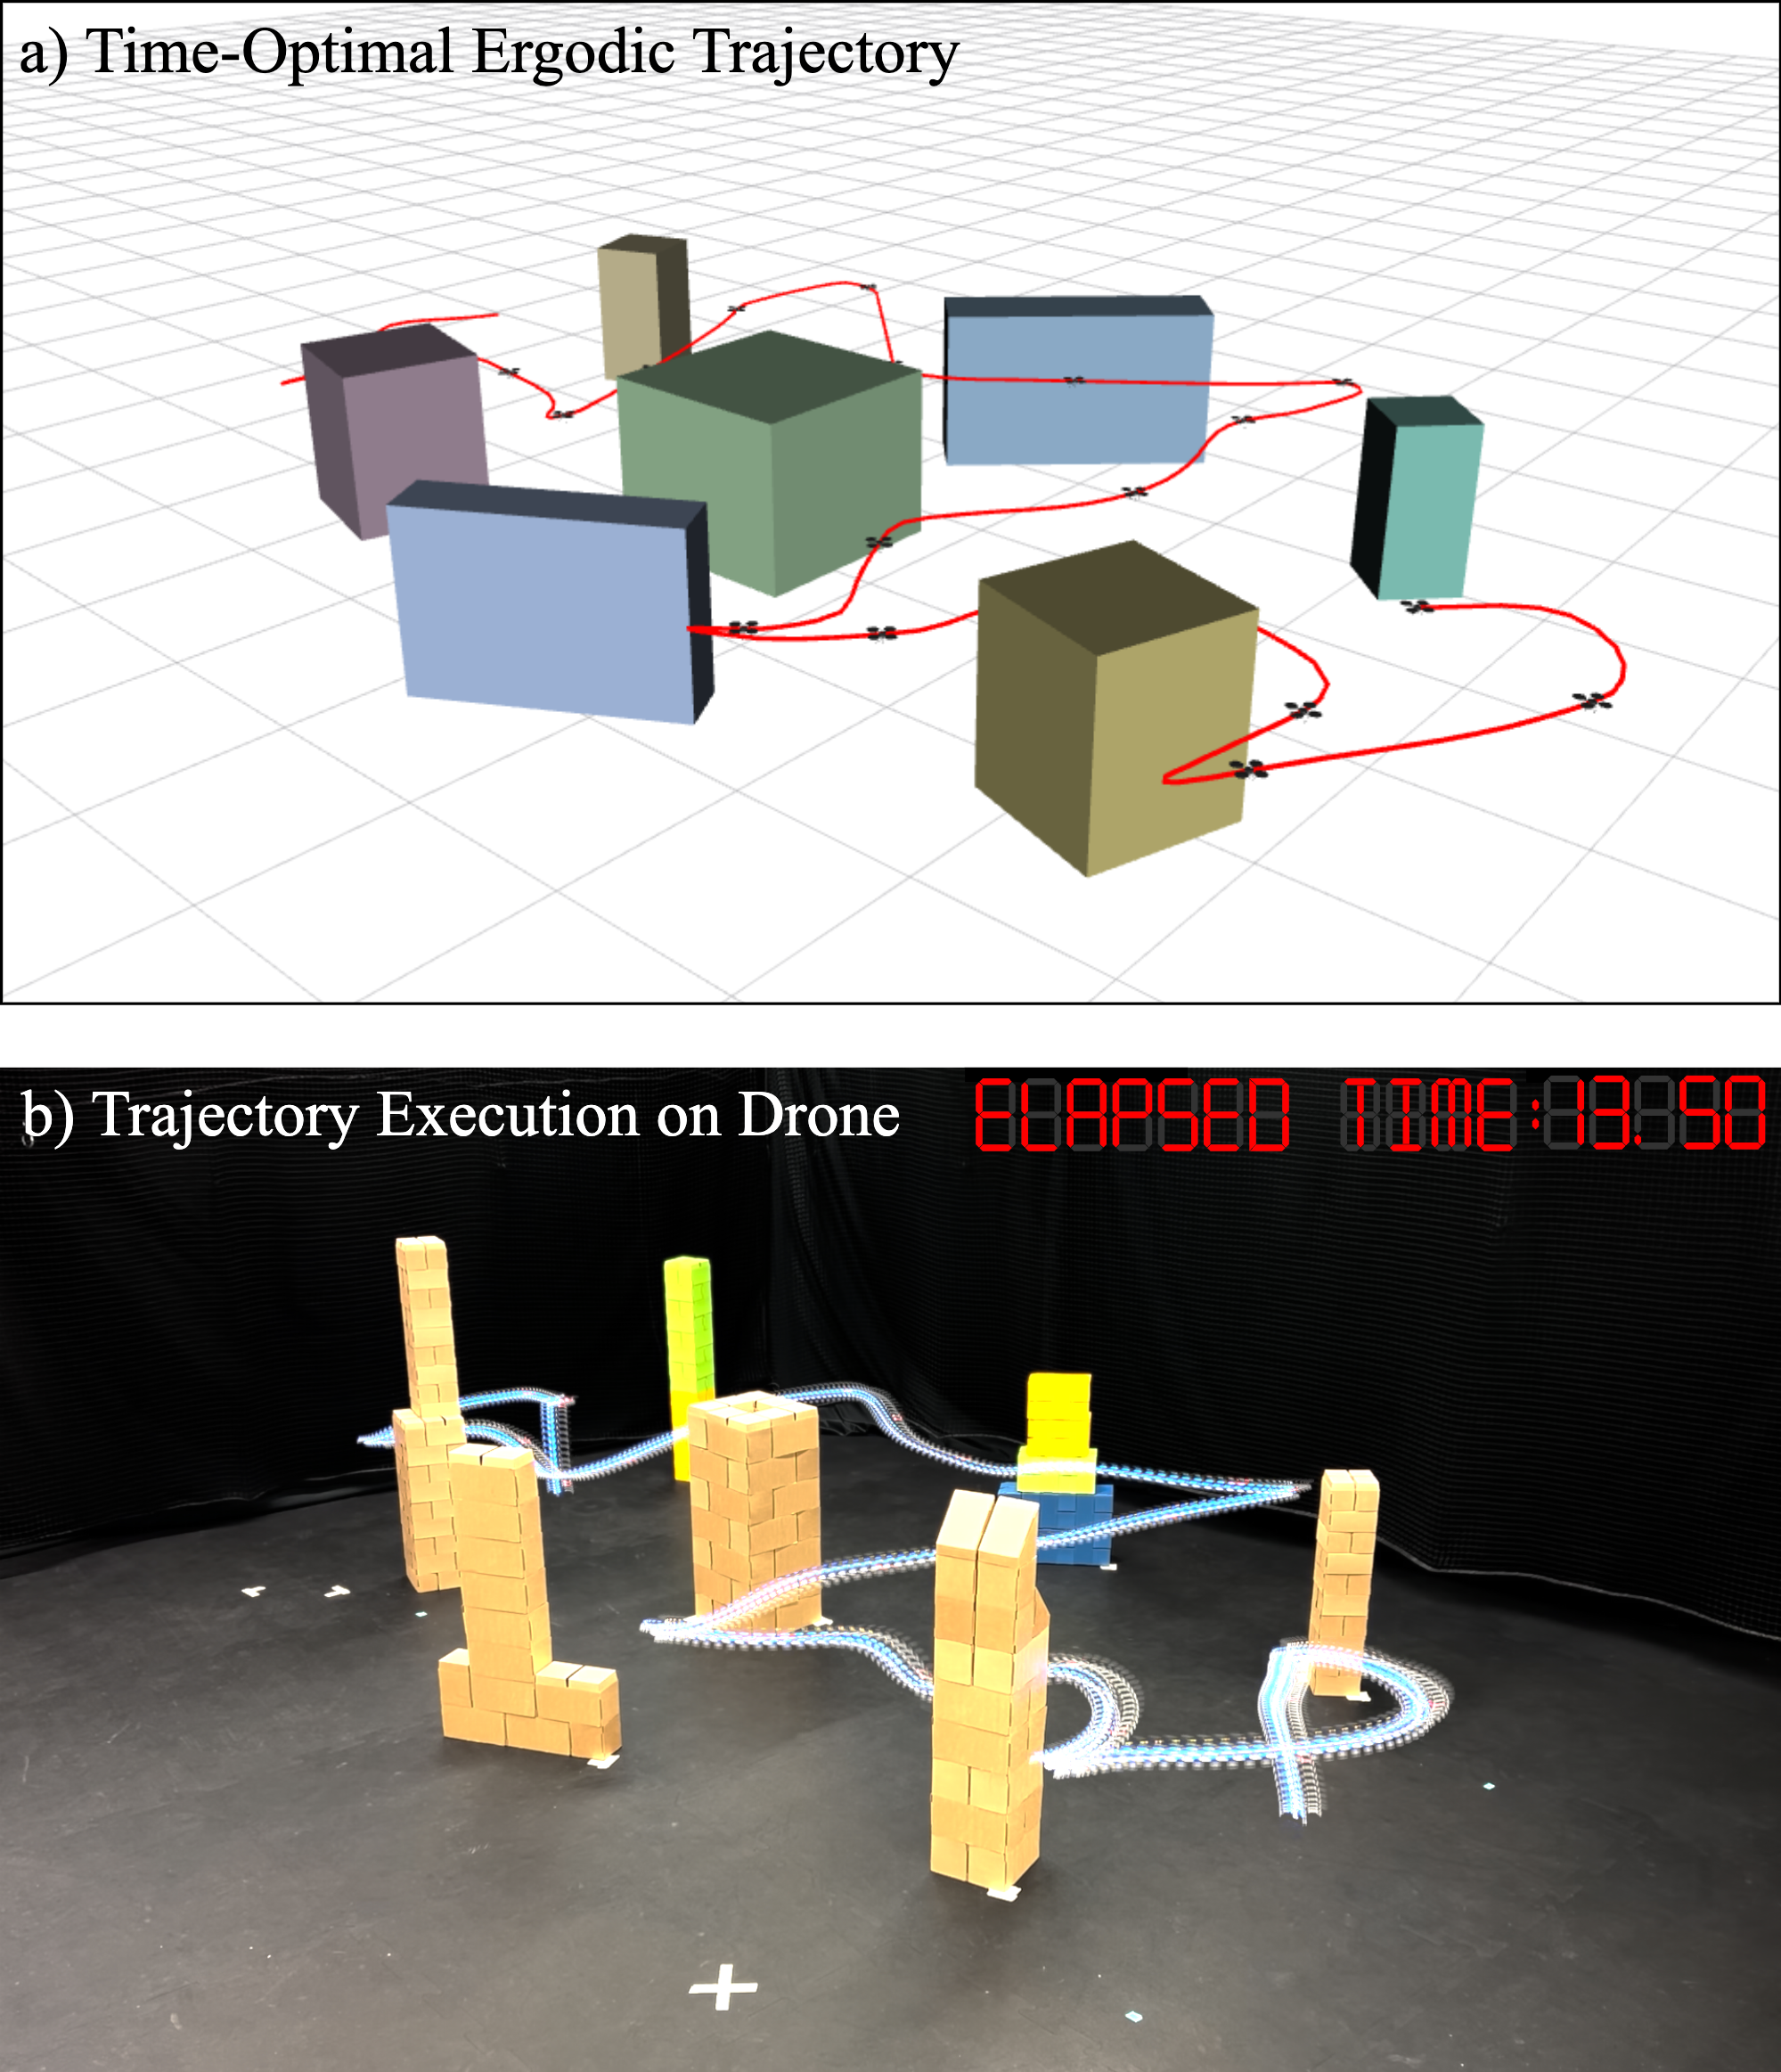
Time Optimal Ergodic Search
Robotics: Science and Systems XIX
·
13 Jul 2023
·
doi:10.15607/RSS.2023.XIX.082
In this paper, we investigate solutions to the time-optimal ergodic search problem for fast and adaptive robotic search and exploration.
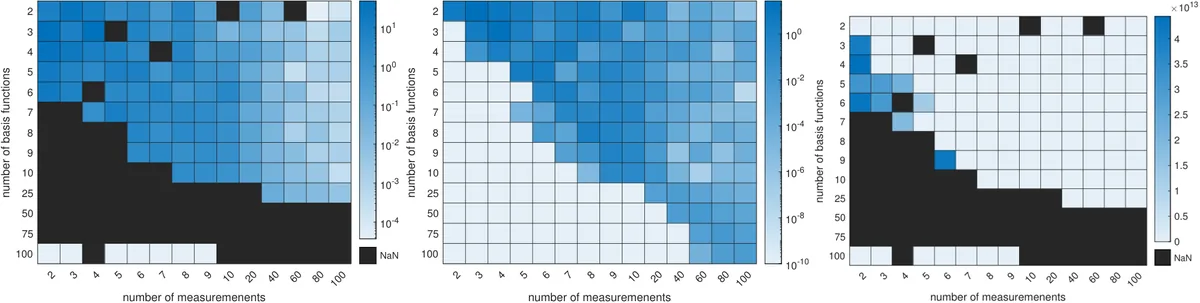
Learning Stable Models for Prediction and Control
IEEE Transactions on Robotics
·
01 Jun 2023
·
doi:10.1109/TRO.2022.3228130
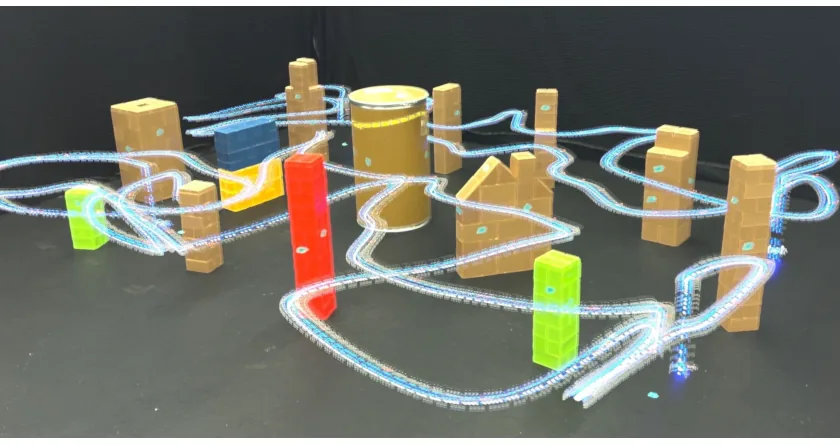
Safety-Critical Ergodic Exploration in Cluttered Environments via Control Barrier Functions
2023 IEEE International Conference on Robotics and Automation (ICRA)
·
29 May 2023
·
doi:10.1109/icra48891.2023.10161032
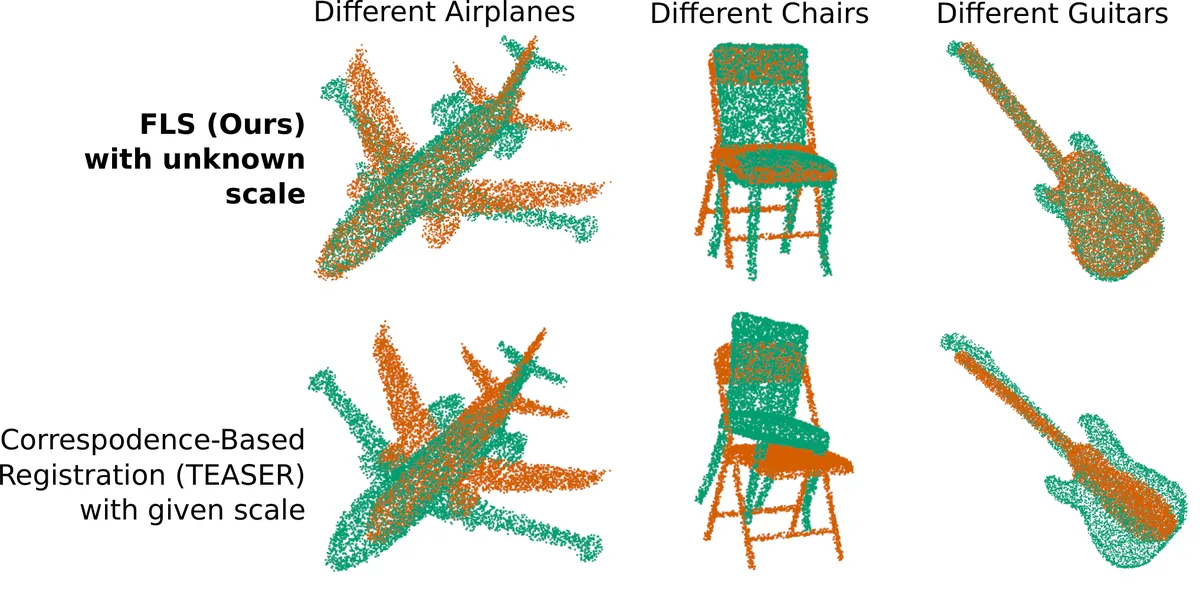
Scale-Invariant Fast Functional Registration
Springer Proceedings in Advanced Robotics
·
01 Jan 2023
·
doi:10.1007/978-3-031-25555-7_11
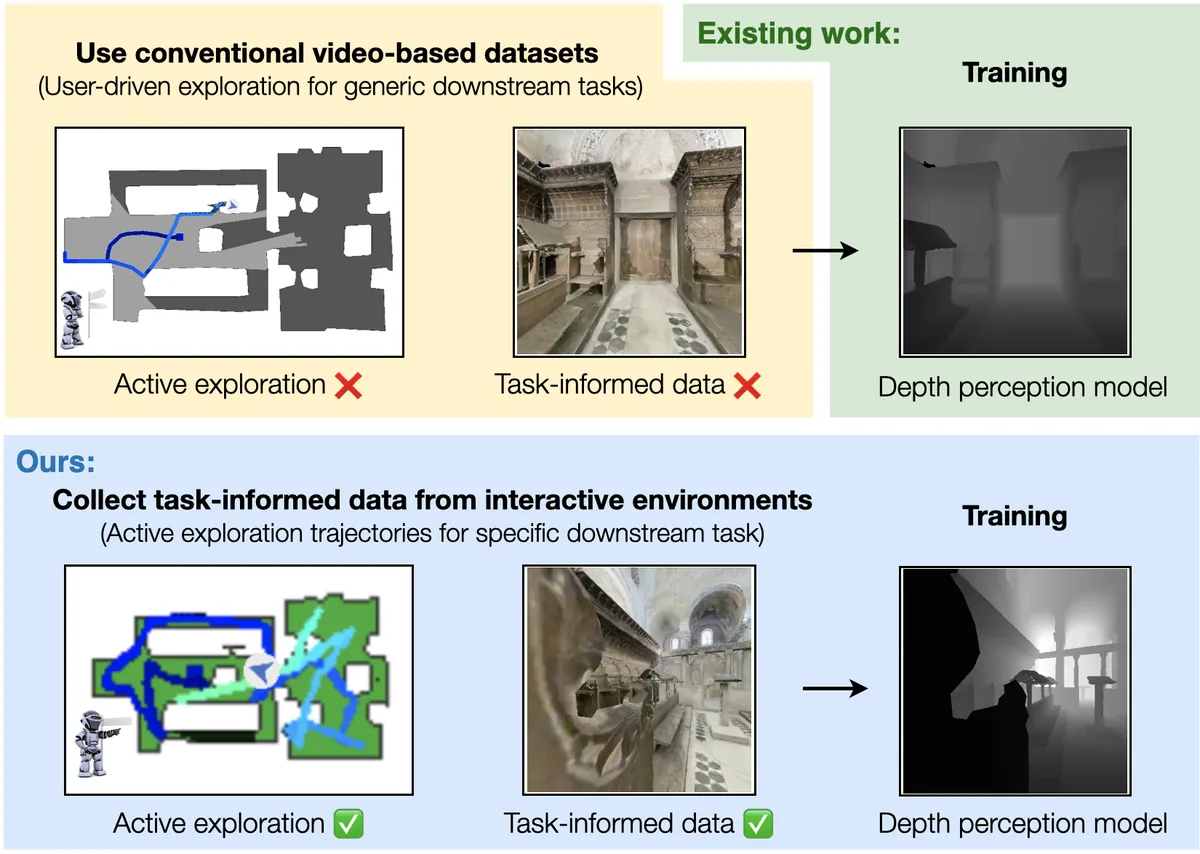
DEUX: Active Exploration for Learning Unsupervised Depth Perception
arXiv
·
01 Jan 2023
·
doi:10.48550/arxiv.2310.06164
2022
A Local Optimization Framework for Multi-Objective Ergodic Search
Robotics: Science and Systems XVIII
·
27 Jun 2022
·
doi:10.15607/rss.2022.xviii.052
Hybrid control for combining model-based and model-free reinforcement learning
The International Journal of Robotics Research
·
02 Jun 2022
·
doi:10.1177/02783649221083331
Multi-Agent Dynamic Ergodic Search with Low-Information Sensors
2022 International Conference on Robotics and Automation (ICRA)
·
23 May 2022
·
doi:10.1109/icra46639.2022.9812037
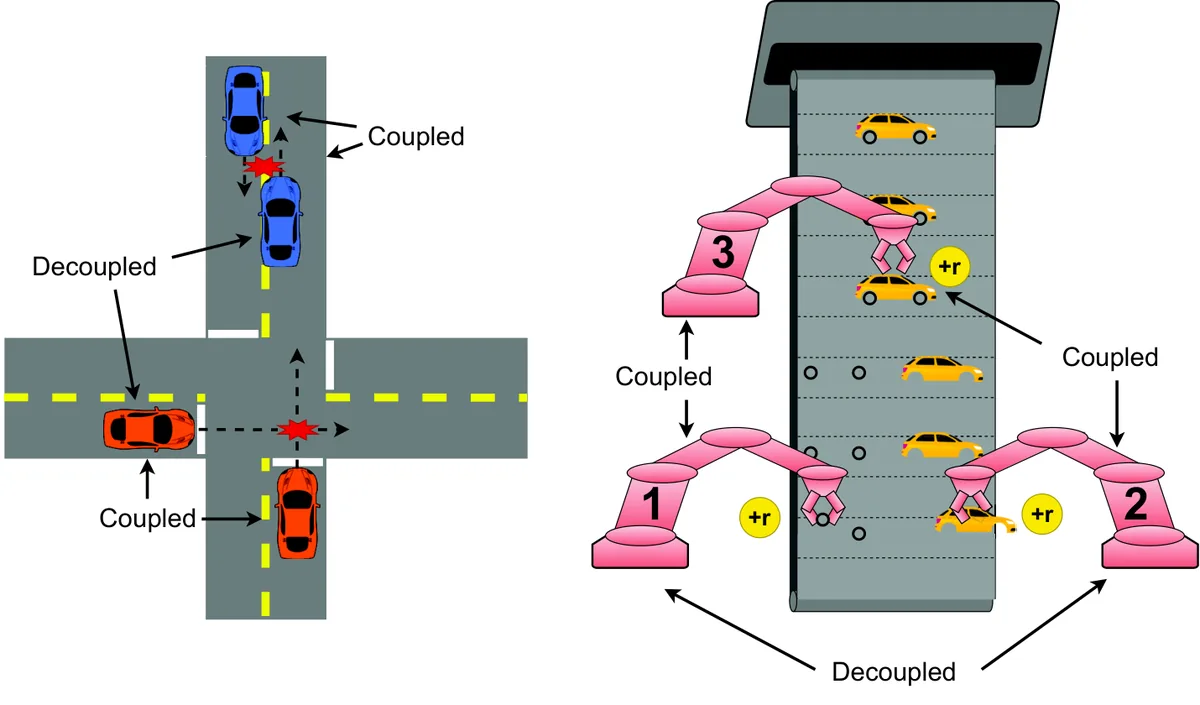
Learning Cooperative Multi-Agent Policies With Partial Reward Decoupling
IEEE Robotics and Automation Letters
·
01 Apr 2022
·
doi:10.1109/lra.2021.3135930
A Second-Order Reachable Sets Computation Scheme via a Cauchy-Type Variational Hamilton-Jacobi-Isaacs Equation
arXiv
·
01 Jan 2022
·
doi:10.48550/arxiv.2203.03865
2021
Linear Policies are Sufficient to Enable Low-Cost Quadrupedal Robots to Traverse Rough Terrain
2021 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)
·
27 Sep 2021
·
doi:10.1109/iros51168.2021.9636011
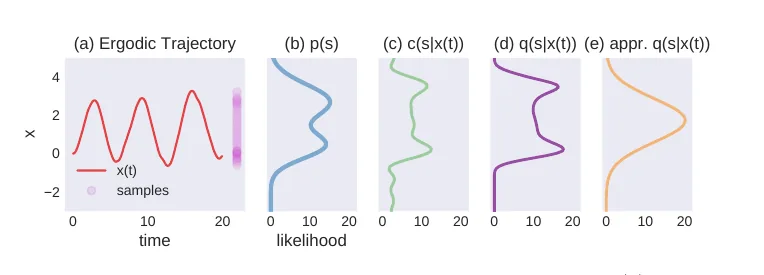
An Ergodic Measure for Active Learning From Equilibrium
IEEE Transactions on Automation Science and Engineering
·
01 Jul 2021
·
doi:10.1109/tase.2020.3043636
A dynamical model for generating synthetic data to quantify active tactile sensing behavior in the rat
Proceedings of the National Academy of Sciences
·
01 Jul 2021
·
doi:10.1073/pnas.2011905118
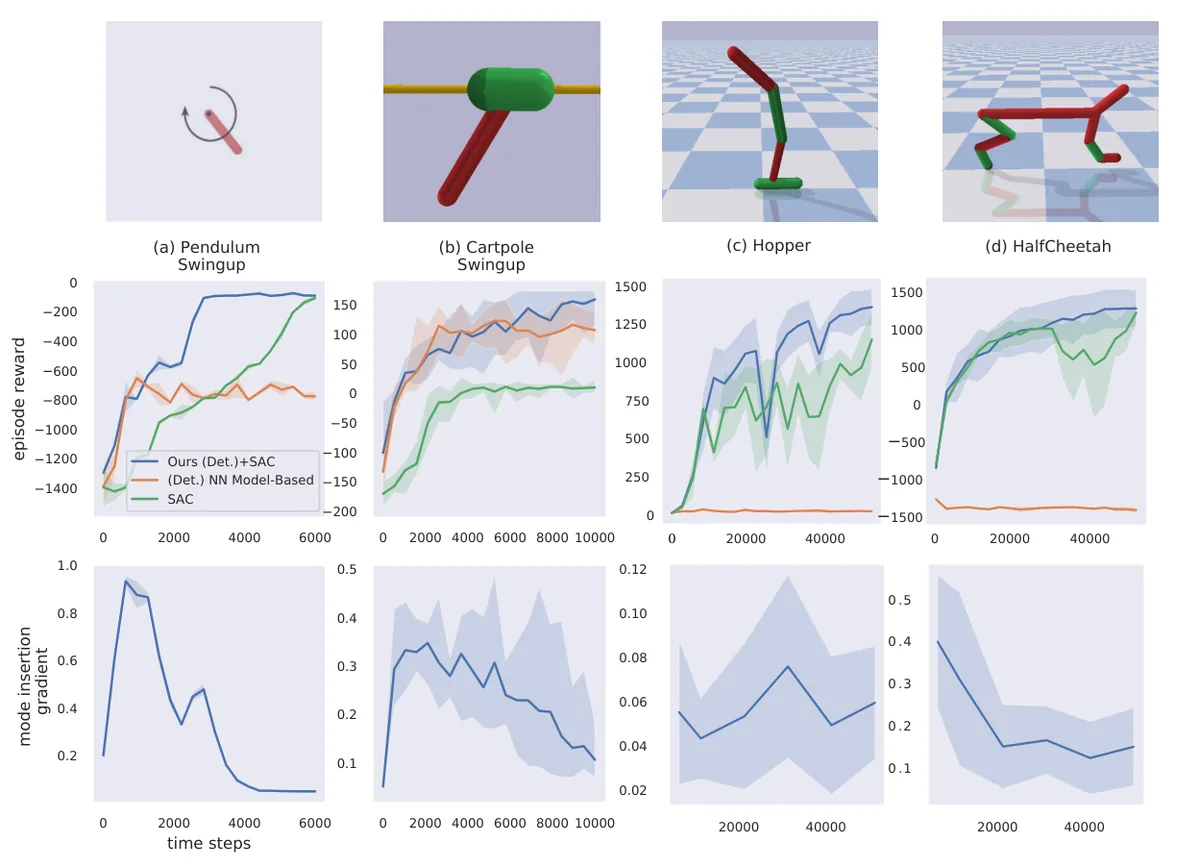
Hybrid Control for Learning Motor Skills
Springer Proceedings in Advanced Robotics
·
01 Jan 2021
·
doi:10.1007/978-3-030-66723-8_27
2020
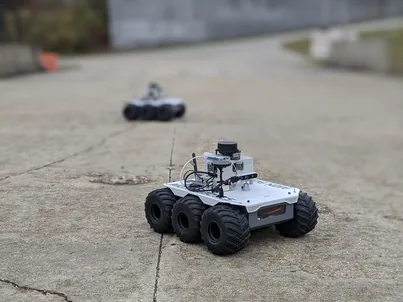
Ergodic Specifications for Flexible Swarm Control: From User Commands to Persistent Adaptation
Robotics: Science and Systems XVI
·
12 Jul 2020
·
doi:10.15607/rss.2020.xvi.067
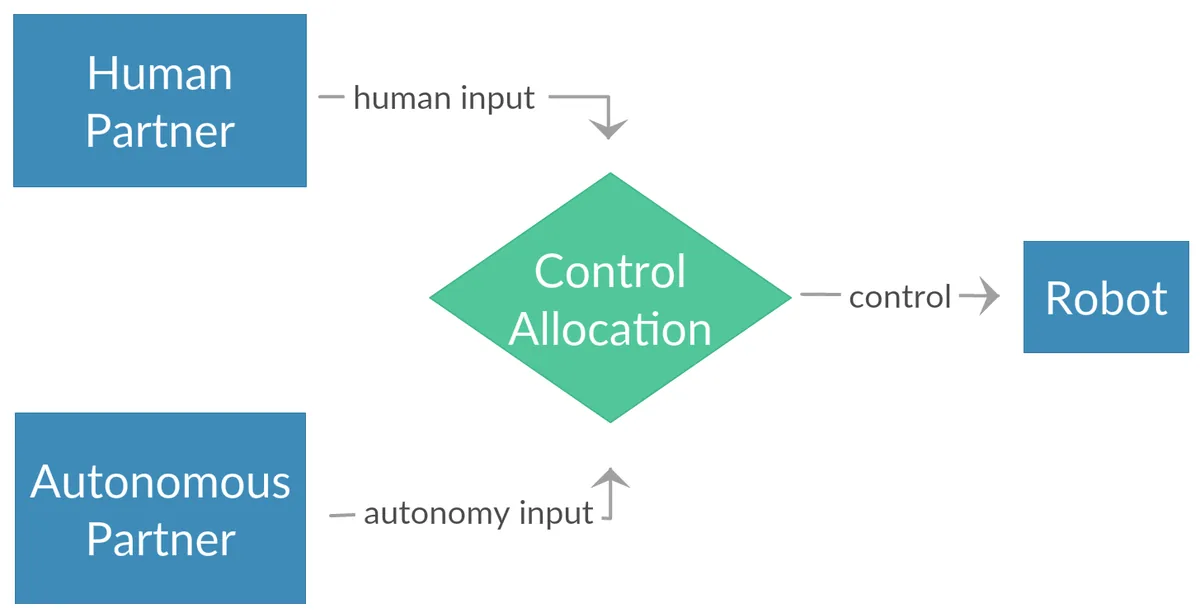
Data-driven Koopman operators for model-based shared control of human–machine systems
The International Journal of Robotics Research
·
10 Jun 2020
·
doi:10.1177/0278364920921935
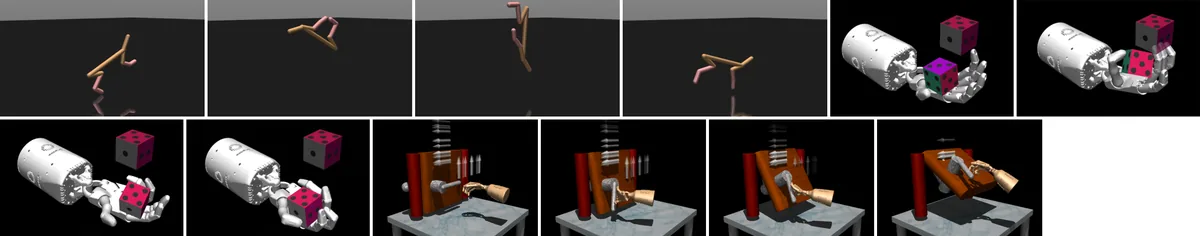
Model-Based Generalization Under Parameter Uncertainty Using Path Integral Control
IEEE Robotics and Automation Letters
·
01 Apr 2020
·
doi:10.1109/lra.2020.2972836
Experimental Applications of the Koopman Operator in Active Learning for Control
Lecture Notes in Control and Information Sciences
·
01 Jan 2020
·
doi:10.1007/978-3-030-35713-9_16
Active Area Coverage from Equilibrium
Springer Proceedings in Advanced Robotics
·
01 Jan 2020
·
doi:10.1007/978-3-030-44051-0_17
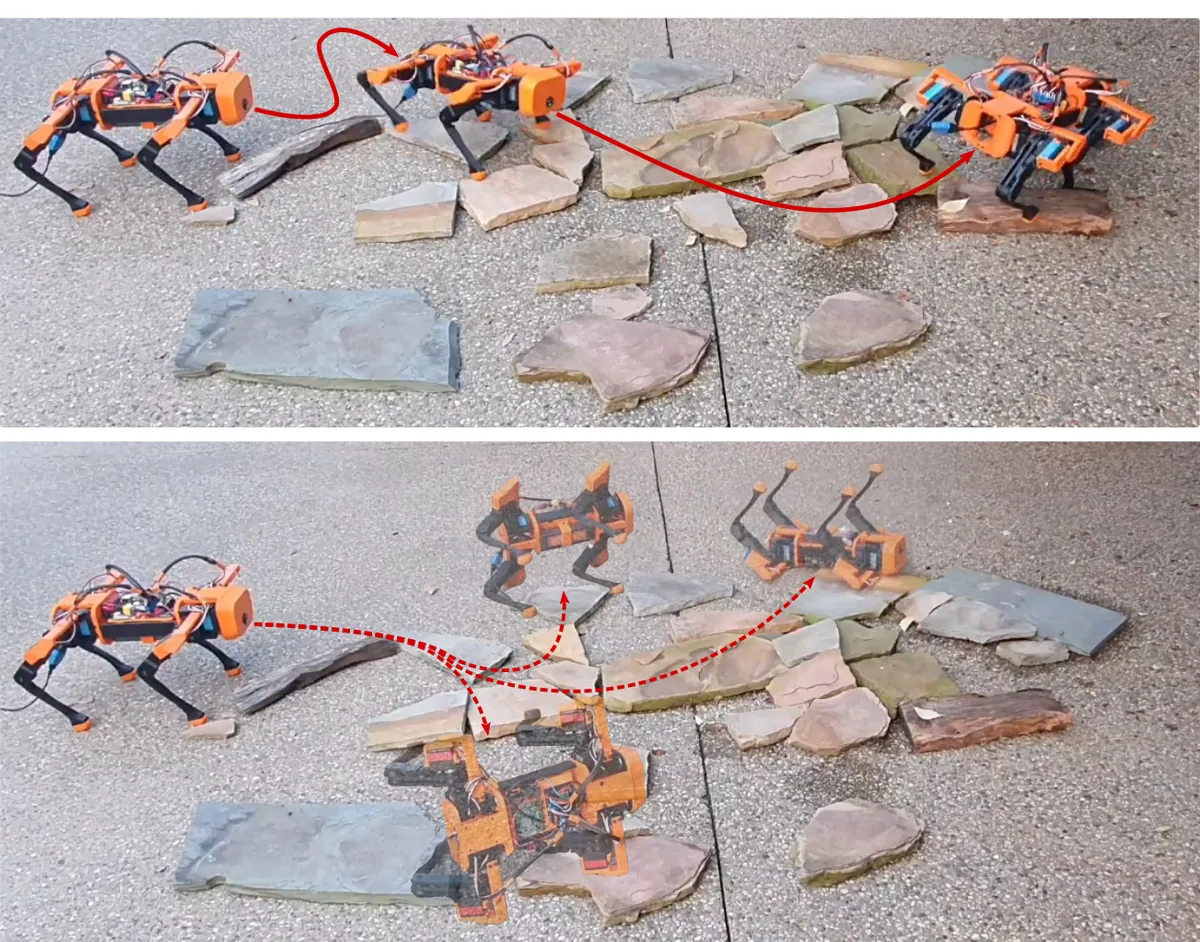
Dynamics and Domain Randomized Gait Modulation with Bezier Curves for Sim-to-Real Legged Locomotion
arXiv
·
01 Jan 2020
·
doi:10.48550/arxiv.2010.12070
2019
WHISKiT Physics: A three-dimensional mechanical model of the rat vibrissal array
openRxiv
·
03 Dec 2019
·
doi:10.1101/862839
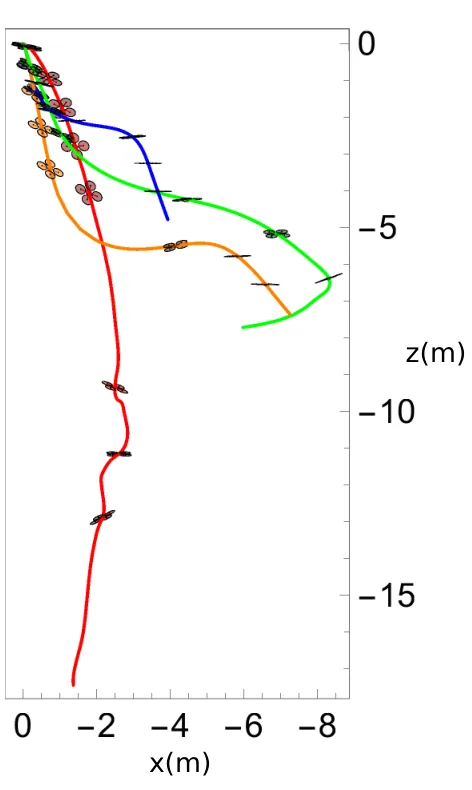
Active Learning of Dynamics for Data-Driven Control Using Koopman Operators
IEEE Transactions on Robotics
·
01 Oct 2019
·
doi:10.1109/tro.2019.2923880
2018
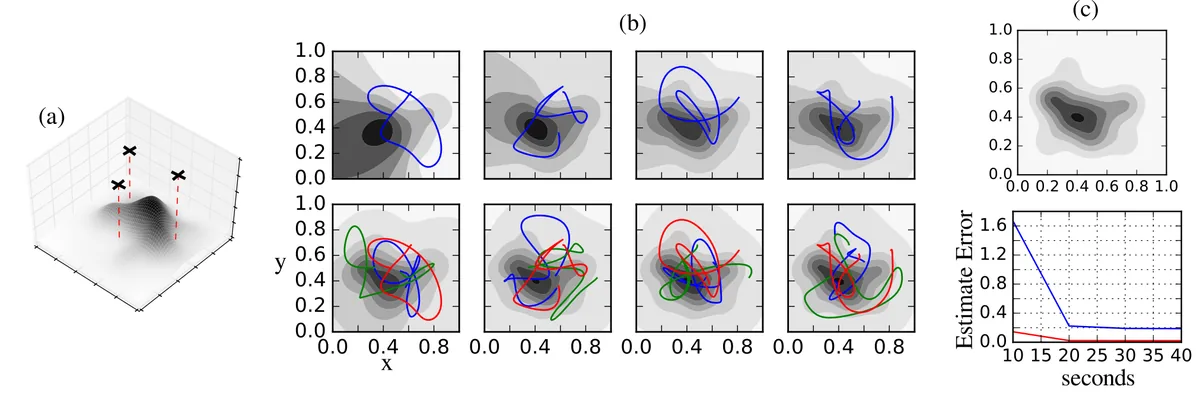
Decentralized Ergodic Control: Distribution-Driven Sensing and Exploration for Multiagent Systems
IEEE Robotics and Automation Letters
·
01 Oct 2018
·
doi:10.1109/lra.2018.2849588
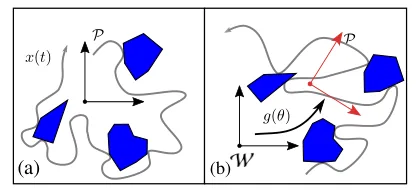
Data-Driven Measurement Models for Active Localization in Sparse Environments
Robotics: Science and Systems XIV
·
26 Jun 2018
·
doi:10.15607/rss.2018.xiv.045
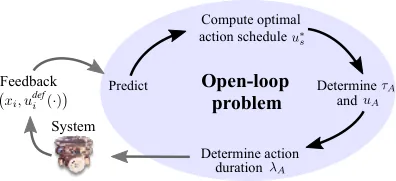
Real-Time Area Coverage and Target Localization Using Receding-Horizon Ergodic Exploration
IEEE Transactions on Robotics
·
01 Feb 2018
·
doi:10.1109/tro.2017.2766265
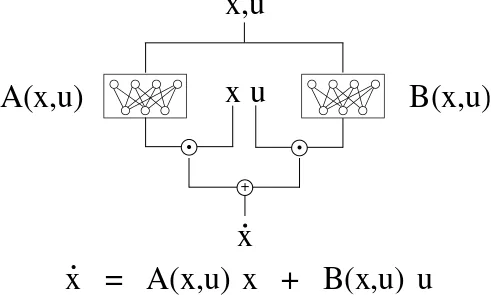
Structured Neural Network Dynamics for Model-based Control
arXiv
·
01 Jan 2018
·
doi:10.48550/arxiv.1808.01184
2017
Model-Based Control Using Koopman Operators
Robotics: Science and Systems XIII
·
12 Jul 2017
·
doi:10.15607/rss.2017.xiii.052
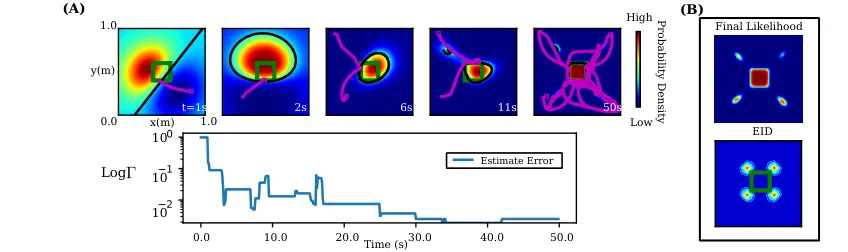
Ergodic Exploration Using Binary Sensing for Nonparametric Shape Estimation
IEEE Robotics and Automation Letters
·
01 Apr 2017
·
doi:10.1109/lra.2017.2654542
2015
Model predictive control of buoyancy propelled autonomous underwater glider
2015 American Control Conference (ACC)
·
01 Jul 2015
·
doi:10.1109/acc.2015.7170893
A Nonlinear Leg Damping Model for the Prediction of Running Forces and Stability
Journal of Computational and Nonlinear Dynamics
·
02 Apr 2015
·
doi:10.1115/1.4028751